
Wolfpine Makes Tenstorrent Kernels Easier to Inspect. It Does Not Predict Their Speed
Wolfpine is a community Python simulator for Tensix accelerators that can run tt-metal programs and expose traces, with an explicit limit on timing accuracy.
On this page
An accelerator simulator can answer two very different questions. “What is my program doing?” is a question about behavior and traceability. “How fast will it run on the card?” is a question about timing fidelity. Wolfpine’s creators make the distinction explicit: the open-source Python project aims to let developers inspect and experiment with Tenstorrent Tensix programs without owning the hardware, while warning that its timing model is not cycle-accurate. [1] [2]
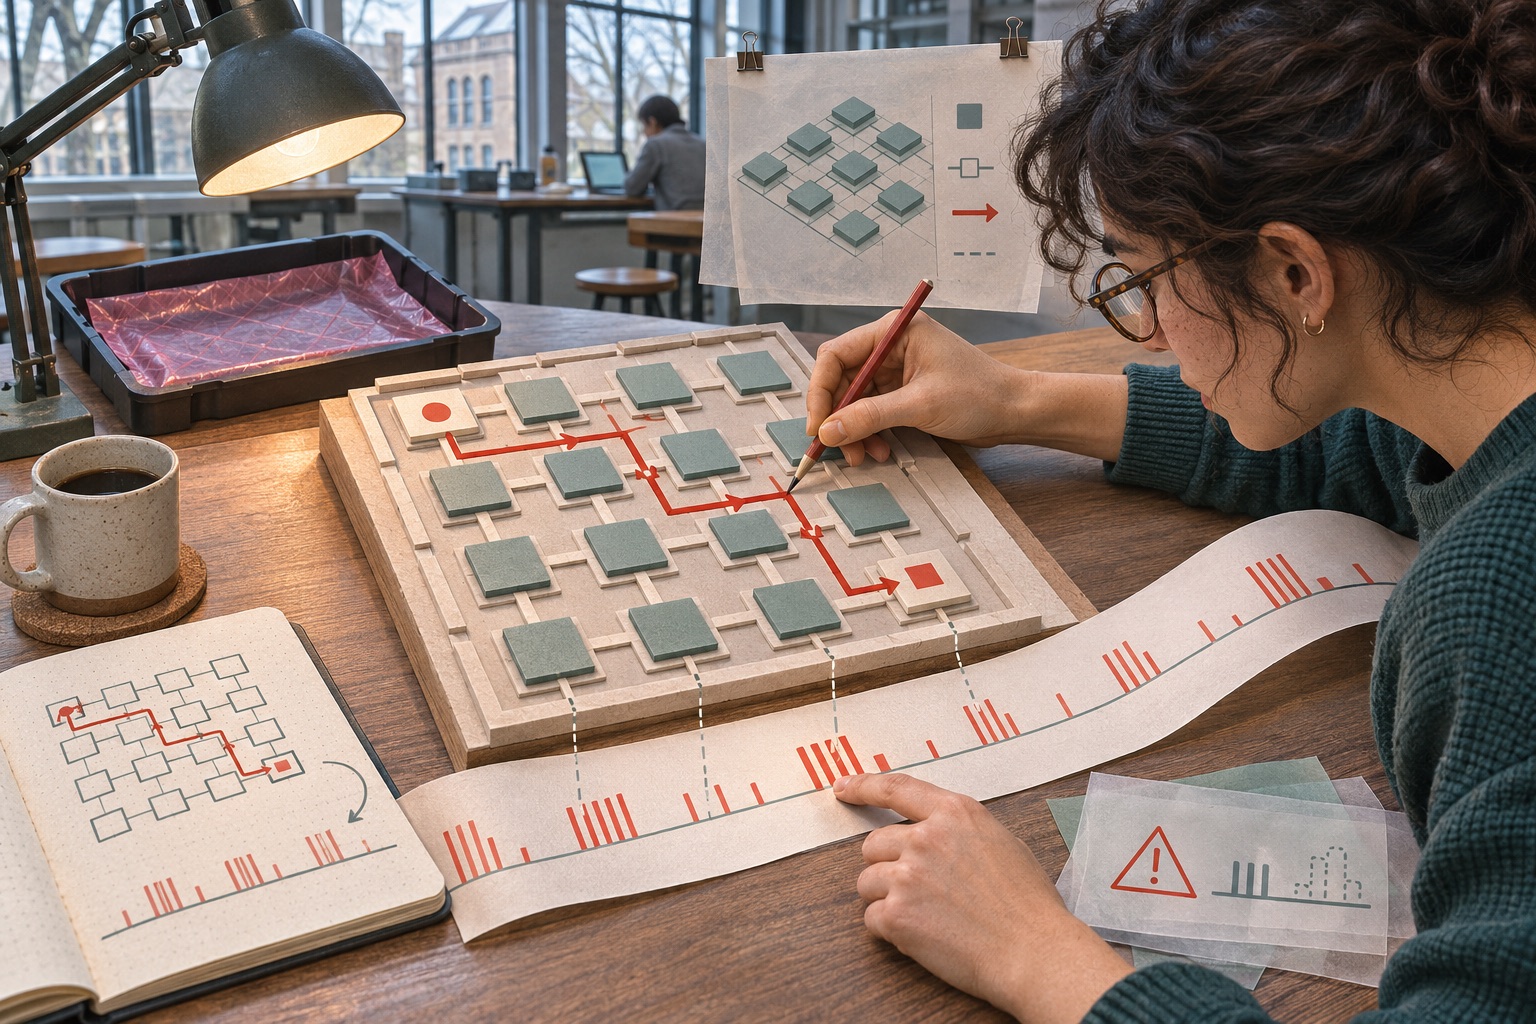
A simulator built for seeing inside a run
The Wolfpine research paper describes a RISC-V simulator for the Tensix architecture that supports Tenstorrent Wormhole and Blackhole generations and integrates with the TT-Metal software stack. The authors say it is written in Python and built from public documentation, open-source software and measurements on physical hardware. It includes typed event streams, component traces and timeline export to help expose behavior that can be difficult to observe directly on the accelerator. [1]
The project repository describes an architecture-agnostic simulator framework with device profiles, RISC-V cores, memory maps, clocks and trace machinery. It says existing tt-metal programs can run against the simulator with a command-line target switch and that the Python implementation lets a driver script inspect internal state. Those are project claims and capabilities documented by the maintainers, not an independent assessment of compatibility across all kernels. [2]
That distinction makes the tool interesting. A researcher without a board can still study control flow, component interactions and a kernel’s use of the simulated architecture. They can instrument the run and examine traces in a familiar programming language. This lowers one barrier to learning and developing accelerator code, even though it does not reproduce every property of the physical device.
The timing limit is part of the design
Wolfpine’s repository is explicit that it is not cycle accurate and is not intended to be. Its timing model is described as a documented floor, charging the low end of published bounds. That may be useful for understanding relative structure or finding where time is consumed in the model, but it is not a trustworthy substitute for hardware performance data. [2]
This is not a small footnote. A simulator can faithfully model the instruction set and still differ from a real system in scheduling, memory contention, interconnect backpressure, firmware behavior, driver overhead, power state or concurrent workloads. An approximate timing estimate can help form a hypothesis, but users should not turn it into a latency or throughput promise for an actual card.
The preprint’s provenance statement is also useful context: it says Wolfpine was built from public specifications and documentation alongside measurements made on physical hardware. That is a method for grounding the model, not an exhaustive proof of equivalence. The paper is a preprint, and its results should be read as a project description rather than as a completed independent certification of every modeled behavior. [1]
Where it fits in a developer’s workflow
A sensible use is to learn the software stack, check how a program interacts with the simulated device, and inspect a trace when a kernel’s structure is unclear. You can use it to test whether code reaches an expected path, explore how components respond, and collect debugging evidence before requesting shared access to hardware.
Then move to a physical device for correctness, timing, thermal behavior, memory-bandwidth questions and production readiness. Keep a test matrix that records the simulator version, target profile, driver and tt-metal revisions, and whether the result was measured on hardware. Do not mix simulated trace timing with measured hardware latency in the same chart unless the two are clearly labeled.
Tenstorrent’s official documentation describes its supported software stack and accelerator products; Wolfpine sits alongside that ecosystem as a community project, not an official vendor simulator. The repository lists a BSD-3-Clause license and presents itself as work in progress. Teams should inspect its source and limitations before making it part of a production engineering workflow. [2] [3] [4]
Better access to a toolchain, not a shortcut around hardware
The most useful contribution of Wolfpine may be participation. Requiring physical accelerator access can limit who experiments with low-level kernels, especially students, independent developers and researchers comparing architecture ideas. A readable simulator with trace outputs can make some learning and debugging tasks possible on an ordinary development machine.
It does not remove the need for hardware. The line between “I understand this program’s path through the model” and “this program meets my service objective” remains a real engineering boundary. In practice, that is a good division of labor: simulate to inspect and iterate; benchmark the supported workload on the actual target; keep the two kinds of evidence separate.
For more context, see our coverage of GPU scheduling for shared accelerator workloads and KV-cache transfer and inference latency.
Frequently asked questions
What does Wolfpine simulate?
Wolfpine is a community-built, pure-Python simulator for Tenstorrent Tensix architectures including Wormhole and Blackhole. The project says it runs real tt-metal programs without physical accelerator hardware and exposes simulator state for inspection.
Is Wolfpine cycle-accurate?
No. The project explicitly says it is not cycle accurate and does not intend to be. Its timing model is an approximate, documented lower-bound model, so it should not be used to predict production performance.
What is Wolfpine useful for?
It can help developers explore program behavior, inspect component-level traces, and experiment with kernels before using physical hardware. Results still need validation on the target accelerator for correctness and performance.
Sources & further reading
Keep reading
Marvell’s Lumentum Deal Targets the Optical Links Inside AI Data Centers
The proposed $115 billion all-stock deal combines Marvell’s connectivity chips with Lumentum’s lasers and optics. Approval and integration remain years away.
Anthropic’s Message Threads Shrink Agent Requests, but Add State to Own
Anthropic’s beta API threads send only new turns, but expire quickly, require replay logic, and are not eligible for zero data retention.
Together Compiler Turns GPU Tuning Into a Continuous Inference Loop
Together’s compiler keeps an optimization engine running across inference experiments, trading setup time and throughput against fidelity and workload fit.
/* Comments */
Comments are offline right now — we reconnect automatically, nothing is lost.